Pick the right lens in four steps, decode our model numbers, read the engineering notes, and download the catalog, model tables and datasheets directly — no forms.
Selection guide · Model naming · Downloads · Insights · Glossary
Check your camera sensor size. The lens image circle must match or exceed the sensor diagonal — e.g. a 2/3″ lens covers 2/3″, 1/2″ and 1/1.8″ sensors.
Magnification = sensor width / field of view. For line scan, use the horizontal pixel count × pixel size over the scan width.
Combine your mechanical space with the magnification/WD range table and cross-check the object-to-image distance (O/I).
C / M42 / M58 / M72 / M90 / M95 / F — verify flange-back distance and clearance against your camera and fixture.
LS2540A-0.24X: LS = line scan lens, 25 = 25mm focal length, 40 = F4.0 aperture, 0.24X = center magnification.
FA1220A: 12mm focal length, 1.1″ format. MC5010A: 1.1″ macro 50mm. The letter suffix indicates the mechanical revision (A / B / C…); a trailing “D” usually marks a large-aperture or revised version.
LD5028-100MP: LD = full-frame lens, 50mm focal length, F2.8, 100-megapixel class (3.1µm pixels).
| Term | Meaning |
|---|---|
| EFL | Effective focal length |
| F No | F-number / aperture range |
| WD | Working distance (object to lens front) |
| Mag. | Optical magnification |
| O/I | Object-to-image (conjugate) distance |
| Image Circle | Maximum sensor format the lens covers |
| TV Dist. | Television distortion |
| RI | Relative illumination |
| Mount | C · M42 · M58 · M72 · M90 · M95 · F |
No forms, no email gate — click and the file downloads. Every catalog model also has its own datasheet on its product page.
Six lens families, complete parameter tables, applications and selection guide — 18 pages.
Download ↓ · 6.8 MBAll 9 labs: interferometers, MTF stations, autocollimators, environmental chambers, with accuracy figures.
Download ↓ · 4.2 MB60+ LS models with focal length, image circle, magnification, mount and WD range — sortable in Excel.
Download ↓ · 21 KB112 model datasheets with MTF, back focus and mechanical drawings — one click from each product page.
Browse models →C / M42 / M58 / M72 / M90 / M95 / F thread specs and flange-back for your camera — confirmed with your RFQ.
Confirm with an engineer →263 mechanical envelopes, 2.7 GB in total — too large to host. Tell us the models and we send the files directly.
Request files →Files open in any PDF reader; the catalog and equipment list keep a searchable text layer, so you can Ctrl+F model numbers inside them.
Practical selection and measurement notes written by the engineers who design and test the lenses — no gated whitepapers.
Match the image circle, compute magnification from FOV, set the working distance, then confirm the mount. Includes model-number decoding and a worked battery-cap example.
Read the guide →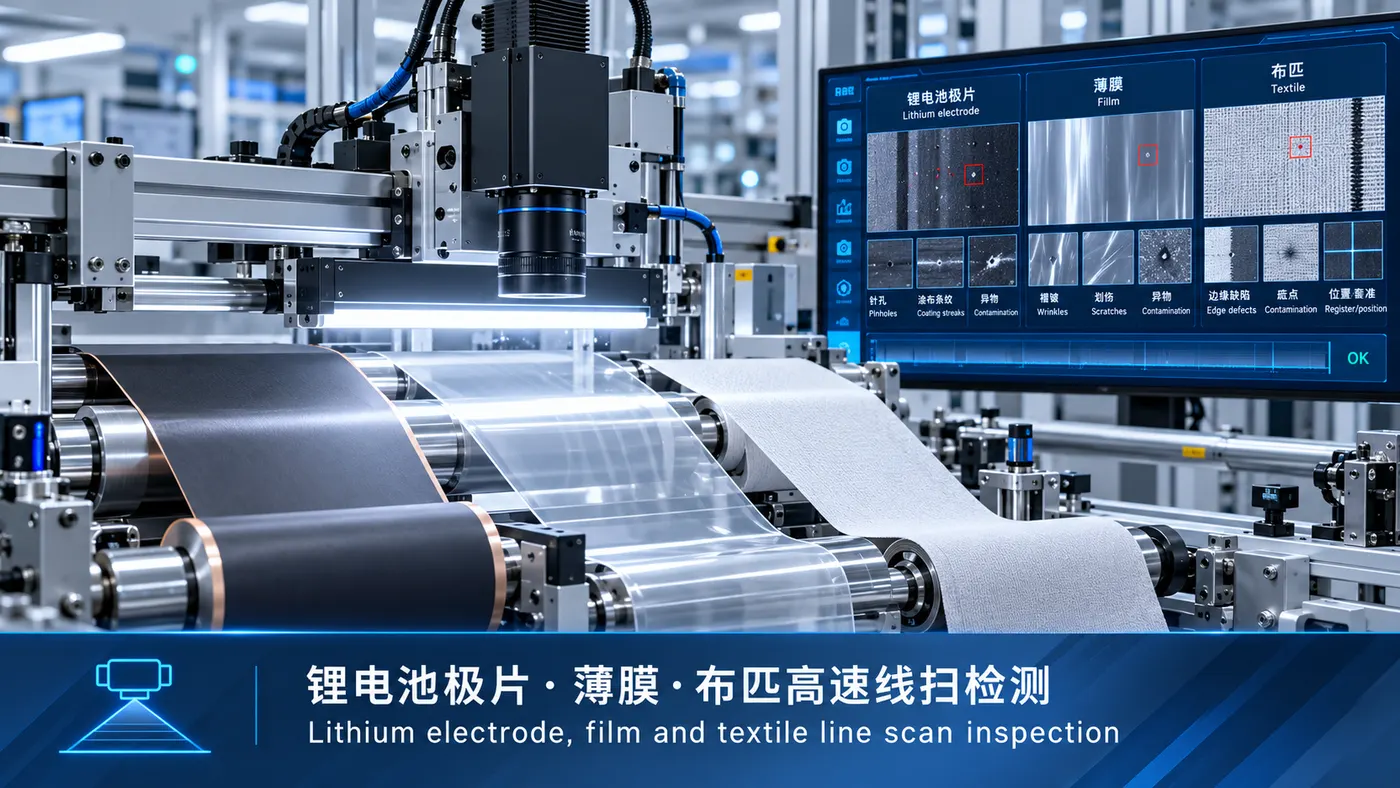
2K to 16K sensor formats and the image circle each one needs, magnification from scan width, O/I conjugate pitfalls, and the three mistakes we see most often in RFQs.
Read the guide →
What MTF at 30 lp/mm actually tells you, how Nyquist links lens resolution to pixel size, why edge MTF matters more than centre, and a 60-second comparison checklist.
Read the guide →Independent references we consider reliable for cross-checking specifications and standards:
54 terms engineers actually use when specifying a lens — from aberration to working distance.
Any departure of a real lens from ideal imaging. The classical set is spherical aberration, coma, astigmatism, field curvature, distortion, plus chromatic aberration (axial and lateral). Industrial lenses are corrected balances of these, not eliminations.
Ratio of focal length to entrance pupil diameter. Each stop down (F2.8 → F4) halves the light but increases depth of field and usually improves MTF. Datasheets list the usable range, e.g. F2.8–F16.
A design corrected so three wavelengths focus at the same plane, minimising colour fringing. Relevant for colour inspection and for white-light metrology.
Distance from the lens mounting flange to the image plane when focused at infinity. C-mount is 17.526mm; M42, M58, M72, M90, M95 and F each have their own. A mismatch means the lens can never reach focus.
Positive distortion: straight lines bow outward toward the edges of the frame, making the image look “bulged.”
1″-32 UN thread, 17.526mm flange-back. The most common mount for area-scan machine vision cameras up to about 1.1″.
Focus or magnification shift with wavelength. Axial (longitudinal) CA blurs colour channels at different depths; lateral CA produces colour fringes that grow toward the edge.
CS-mount has a 12.526mm flange-back — 5mm shorter. A 5mm adapter lets a C lens work on a CS camera; the reverse is impossible.
Light delivered through the lens axis via a beamsplitter, so illumination travels the same path as imaging. Standard for specular surfaces such as wafers, glass and polished metal.
Thin-film layers that cut surface reflection from about 4% per surface to well under 1%. Multi-coating matters most in multi-element lenses and in scenes with strong backlight or highly reflective parts.
Angle at which the principal ray hits the sensor. Sensor micro-lenses are designed for a specific CRA; mismatch causes shading and colour error at the corners — check it when pairing a short focal length with a large sensor.
Range of object distance that stays acceptably sharp. Grows with F-number and working distance, shrinks with magnification. Often specified at a circle of confusion equal to 2 pixels.
Deviation of imaged position from ideal position, expressed as a percentage of image height. Below 0.1% is metrology grade; 0.1–0.5% is fine for defect detection; above 1% needs software correction.
The resolution ceiling set by aperture alone: beyond roughly 1500/F# lp/mm no design can do better, so stopping down past the optimum F-number costs sharpness even as it gains depth of field.
The apparent aperture seen from the object side (entrance) and image side (exit). Their positions drive chief-ray-angle behaviour, which matters on sensors with microlens shading.
Distance from the rear principal plane to the image plane for an object at infinity. Combined with the sensor size, it determines the field of view.
The aperture as seen from the object side. Its diameter, not the physical iris diameter, sets the true F-number — which is why two lenses with the same F/# can pass different amounts of light.
Nikon bayonet mount, 46.5mm flange-back. Used on large-sensor cameras and some high-resolution line scan and 100MP configurations.
Extent of the object that the sensor images. FOV = sensor size ÷ magnification. Given first in almost every serious RFQ.
See Back Focal Length. The mechanical datum that decides whether a lens physically focuses on a given camera.
Stray images and veiling glare caused by reflections between lens surfaces. They look like low-contrast haze or a bright artefact opposite a strong light source, and they are the usual cause of unstable thresholding.
The thread on the front of the barrel for screw-in filters. Check it before ordering bandpass or polarising filters; industrial lenses often use non-standard sizes such as M27, M30.5 or M35.5.
The inverse of a telecentric: rays converge from beyond the object, imaging the outside of a cylindrical part in one shot. Used with 360° wall inspection optics for inner/outer wall scanning.
Diameter of the circle the lens actually illuminates. It must equal or exceed the sensor diagonal. A 1.1″ lens covers 1.1″ and everything smaller.
Historic vidicon-tube sizes, not the sensor diagonal. 2/3″ is an 11mm diagonal; 1.1″ is about 17.6mm. Always work from the actual diagonal when in doubt.
Manual iris is set once and locked; motorized (DFA) iris and focus are driven by the controller, which is what mixed-model lines need when lighting or object height changes between batches.
Unit of spatial frequency: one dark bar plus one light bar. The standard x-axis of an MTF curve.
A lens corrected for a sensor that is one pixel row tall. Specified by image circle (φ30mm for 2K up to φ82–φ90mm for 16K), magnification band and working distance range.
Metric thread mounts used where C-mount's 17.5mm flange-back or 1″ thread is mechanically inadequate — mainly line scan and large-format lenses.
Image size ÷ object size. β = sensor width ÷ FOV. Below ~0.1X is wide-field work, 0.1–1X is macro territory, above 1X is microscopy.
Contrast transfer versus spatial frequency, 0 to 1. The honest way to compare two lenses — but always compare edge values, not just the centre.
Image size divided by object size. Below about 0.1X most machine vision work uses fixed focal lenses; above it, macro and telecentric designs take over because distortion and working distance behave differently.
Highest spatial frequency a sensor can resolve: 1 / (2 × pixel size). A 3.1µm pixel Nyquist-limits around 161 lp/mm. Buying lens resolution beyond this is wasted budget.
Total conjugate distance from object plane to sensor plane. The number machine designers need — it is longer than the working distance by the lens length plus back focus.
The ″ inch size of a sensor is a legacy tube diameter, not a real diagonal: a 1″ sensor is about 16mm diagonal, 2/3″ about 11mm. Always size lenses from the true diagonal in millimetres.
Centre-to-centre spacing of sensor pixels, in µm. Smaller pixels raise resolution but lower sensitivity and raise the Nyquist limit the lens must satisfy.
Theoretical reference plane inside the lens from which focal length is measured. Needed for accurate conjugate calculations at high magnification.
Negative distortion: straight lines bow inward near the edges. It is the sign convention opposite to barrel distortion and is common in telecentric and long focal length designs.
Centre-to-centre distance between sensor pixels, in µm. Smaller pitch demands a higher-resolution lens; 3.45µm pixels need roughly twice the lp/mm of 6.9µm pixels to show the same detail.
Corner brightness as a percentage of centre brightness. Below roughly 60% you will see visible shading that flat-field correction must remove, amplifying corner noise.
Smallest reliably distinguishable feature. For a lens it is an MTF-limited property, not a single number — always quote the frequency and the contrast criterion together.
Line pairs per millimetre resolved on the sensor. It is the honest way to compare lenses, because a 5MP lens on a 5MP camera can still be the weak link if it only resolves at low contrast.
Corner brightness as a percentage of centre brightness. Below about 60% the vignetting starts to interfere with grey-level inspection; ask for the curve rather than a single number.
Physical size of the imaging area. Common machine vision formats: 1/2.9″, 1/1.8″, 2/3″, 1″, 1.1″, 4/3″, full frame, plus line scan 2K/4K/8K/16K.
Gradual brightness fall-off from centre to edge, caused by relative illumination limits and by cos⁴ fall-off. Corrected by flat-field calibration.
Wavelength band a lens is corrected and coated for. A standard visible design used at 850nm will show focus shift; ask for a near-IR corrected version if you light with IR.
A lens whose entrance pupil sits at infinity, so magnification does not change with object distance. Removes parallax error in gauging — at the cost of size, weight and price. Object-space, image-space and bi-telecentric variants exist.
1/f = 1/u + 1/v, with magnification β = v/u. Accurate enough for first-pass machine layout; datasheet WD tables take over for the final design.
Distortion measured as the worst bow of a straight line across the field, expressed as a percentage of image height. It is the number industrial datasheets quote, and it is smaller than geometric distortion for the same lens.
How parallel the chief rays stay across the field. A telecentric lens keeps magnification constant as object distance varies, which is why it is used for gauging rather than for plain inspection.
Severe corner darkening or actual clipping of the image circle. Almost always means the lens image circle is smaller than the sensor — a selection error, not a defect.
Distance from the front of the lens (or a stated datum) to the object. Datasheets give a centre WD plus a range over which the specified MTF holds.
Deviation of the emerging wavefront from a perfect sphere, usually in wavelengths (λ). Our testing center measures to RMS ≤ 1/200λ at 632.8nm.
A true zoom holds focus while focal length changes; a varifocal does not and must be refocused. For machine vision, fixed focal or telecentric designs are preferred because moving groups lose repeatability.
Send your camera model, FOV and working distance — we reply with a complete proposal and sample-shooting advice within one business day.
Filter 114 current models by sensor format, focal length, mount and magnification — or enter your sensor, working distance and field of view and get the required focal length plus the models that meet it. No sign-up, no download.